robonix.skill.find_item
skill package
v0.1.0
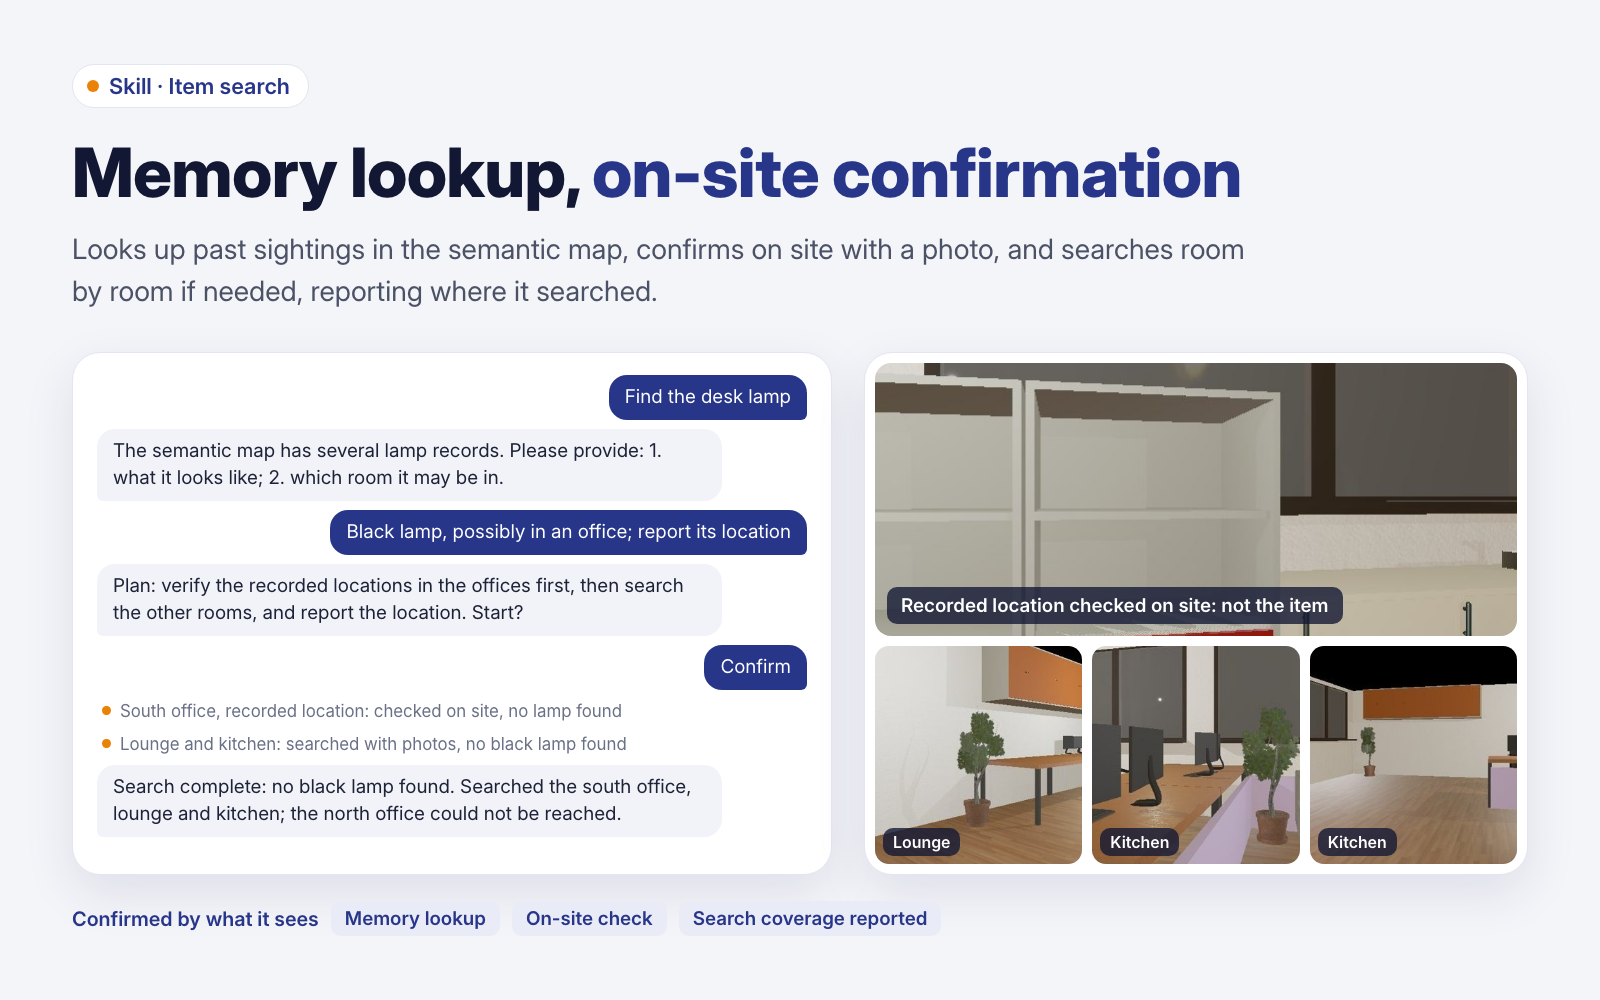
Find a lost item from what the robot remembers, then search room by room, after asking what it looks like.
README
skill-find-item-rbnx@main
Find an item
Finds a lost item from what the robot remembers, then searches room by room, after asking what it looks like. A Robonix skill package (robonix.skill.find_item).
The skill is a procedure: its CAPABILITY.md tells Pilot what to ask the user before starting, to confirm the plan, which calls to make in which order, how to report progress, and the format of the final report. The calls themselves are typed MCP contracts (robonix/skill/find_item/{look_at, look_in}).
Every move goes through robonix/service/navigation/navigate; the skill never drives the chassis itself.
Requirements
- A mobile base with navigation (
robonix/service/navigation/navigateand itsstatus). - Scene with a saved map and named regions (
robonix/system/scene/goal_region,goal_near,list_regions,find). - An RGB camera (
robonix/primitive/camera/snapshot). - A Pilot model that can read images.
Tested in the Robonix Webots example (TIAGo in the office world).
Use
skill:
  - name: find_item
    url: https://github.com/syswonder/skill-find-item-rbnx
    config:
      nav_timeout_s: 180
      save_dir: ""        # optional: also write every photo here