The Robonix package catalog.
Skills, services, primitives, and complete robot deployments, published by the community. Every entry is read straight from its own repository's manifest, so what you see here is what the package actually declares.
Skills
Task-level providers that compose services and primitives into something a robot can be asked to do.
Robot deployments
Repositories that assemble a whole robot: body description, drivers, services, skills, runtime configuration.
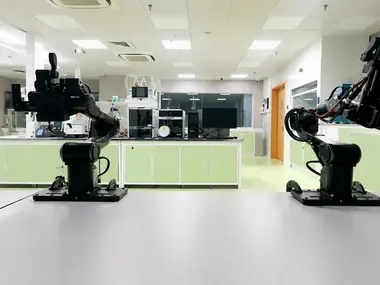
Robonix deployment for two AgileX Piper arms and their factory CAN grippers.
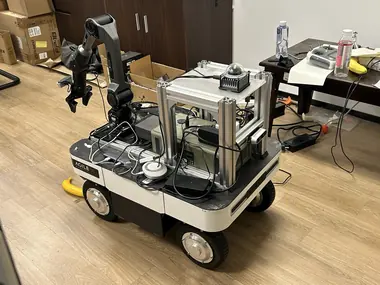
Robonix deployment for the AgileX Ranger Mini v3 robot.
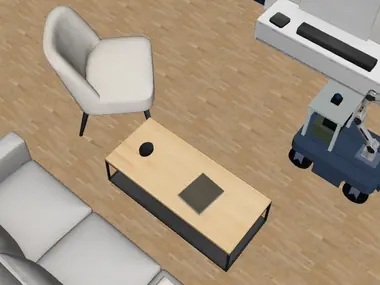
Selectable Web/native MuJoCo simulation of Ranger Mini V3 and Piper for Robonix.
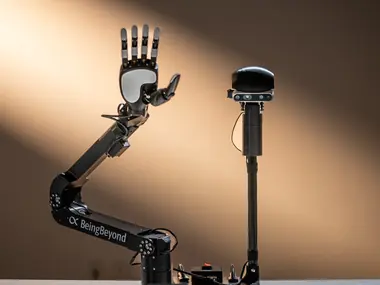
BeingBeyond D1 desktop robot deployment — dexterous-hand object pick/place skill.
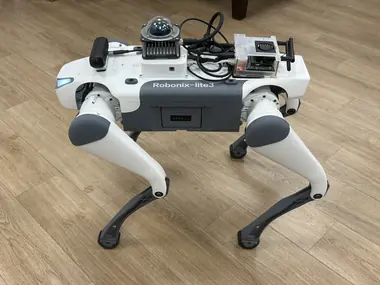
Minimal Robonix deployment for the Deep Robotics Lite3.
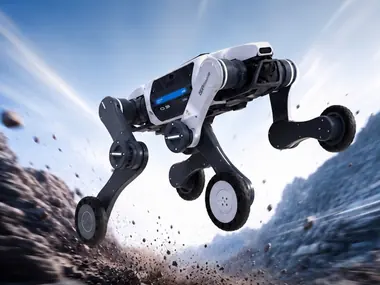
DeepRobotics Lynx S10 wheeled-quadruped deployment — Orbbec RGB-D sensing, Lynx UDP chassis control, and InternVLA vision-language navigation.
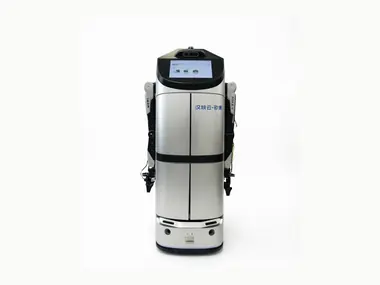
Robonix deploy manifest for the Hantewin Benben
LinkerHand O6 standalone dexterous-hand deployment — finger dance and static gesture skill.
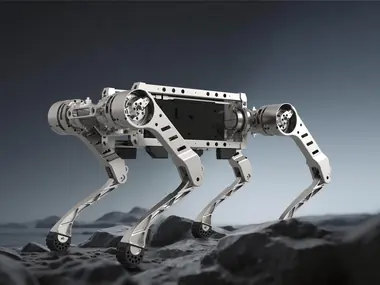
Dockerized MirrorMe BPX deployment with odometry and guarded stand/sit posture control.
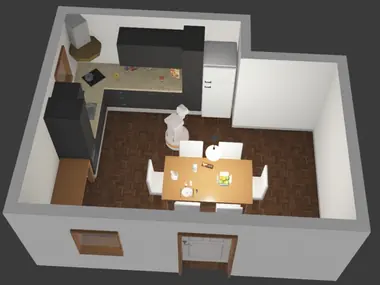
Webots TIAGo Lite simulation deployment — differential-drive base, head RGB-D camera, planar lidar, audio, mapping, navigation and exploration, with no robot hardware required.
Robonix deployment for an autonomous Minecraft player.
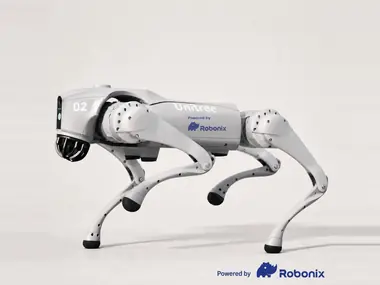
Safe Robonix deployment for Unitree Go2 with mapping, semantic navigation and read-only UI.
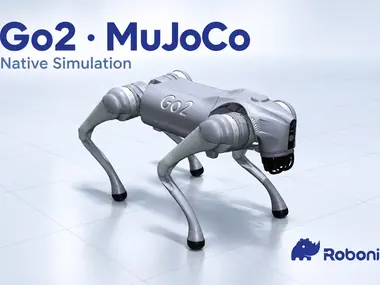
Web/native MuJoCo Go2 simulation with exploration and Scene semantic navigation.
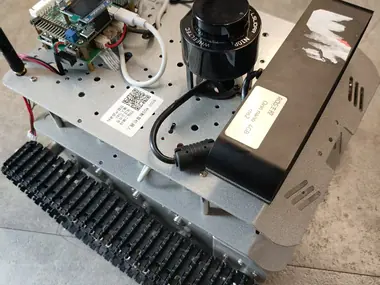
Wheeltec R550 mini_tank — 2D SLAM mapping deploy (N10P lidar + rtabmap).
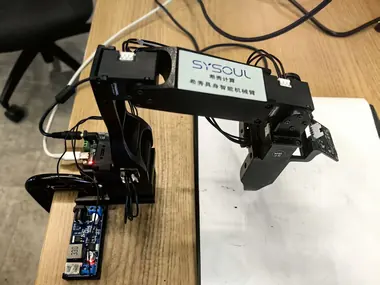
Roboarm LeRobot Koch 五自由度机械臂 Robonix 部署。
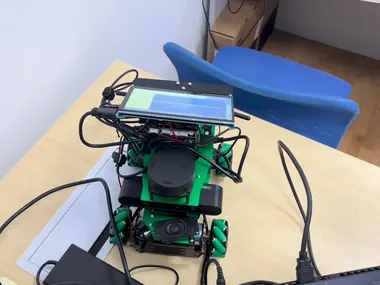
Guarded short-distance ROS 1 navigation for the Yahboom ROSMASTER X3.
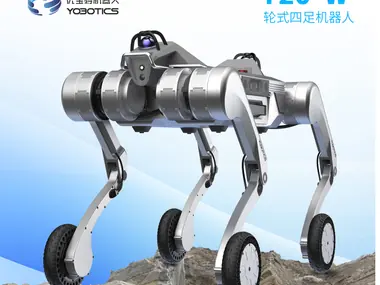
Robonix robot deployment with Livox LiDAR, RealSense camera, chassis control, navigation, speech and scene understanding.
The substrate
What skills are built on. Providers of the same capability are interchangeable, so a skill written once runs on any robot that has them.
Publish a package
Your code stays in your repository. Listing it
takes one entry in catalog.yaml — everything else is read from your manifest.
packages:
  - name: robonix.service.mapping
repo: https://github.com/syswonder/service-map-rbnxRead it as an API
The whole catalog is static JSON on the same host. No key, no rate limit, no query parameters — fetch it and filter on the client.
curl -s https://packages.robonix.ai/api/v1/packages.json