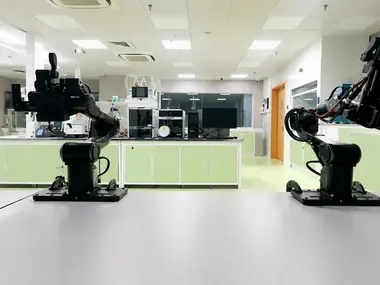
Robonix deployment for two AgileX Piper arms and their factory CAN grippers.
Complete robot deployments, and the packages each one assembles.
Robonix deployment for two AgileX Piper arms and their factory CAN grippers.
AgileX Piper 6-DOF arm + LinkerHand O6 dexterous hand (right), MuJoCo simulation body package for Robonix. The skill drives the sim process via its HTTP API (control/state/sim endpoints).
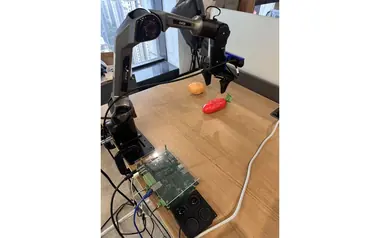
AgileX Piper with Orbbec Gemini 336L, RK3588 NPU YOLO and Python IK for vertical grasping.
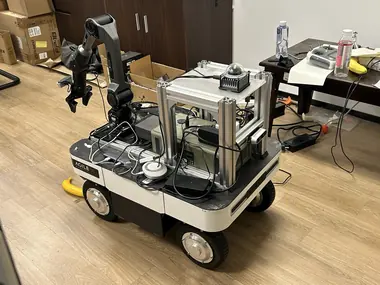
Robonix deployment for the AgileX Ranger Mini v3 robot.
Robonix x MiniCPM-RobotTrack person-following deployment for the AgileX Ranger Mini v3, reproducing the Go2 reference (robot-unitree-go2 PR #6) with the chassis swapped: ranger_chassis + chassis guard replace go2_chassis + its SDK daemon. Everything else -- the source mux, the Nav2 velocity smoother, the velocity guard, the Pilot/Executor capability path and the Chinese follow-distance router -- is carried over. Runs only while the navigation deployment (robot-agilex-ranger_mini_v3) is stopped: both own can_ranger.
Robonix x InternVLA-N1 (DualVLN) instruction-following deployment for the AgileX Ranger Mini v3. One navigation instruction goes out to the remote DualVLN server, one discrete step or short trajectory comes back per frame, and it is executed as a velocity on the Ranger chassis behind the Ranger chassis guard. The model server is NOT part of this deployment: it runs on a compute host with its own GPU and is reached over the network.
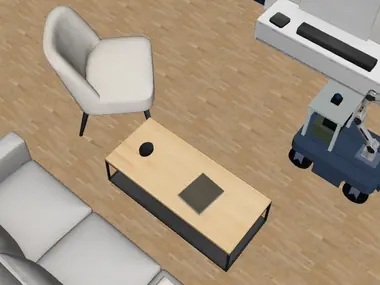
Selectable Web/native MuJoCo simulation of Ranger Mini V3 and Piper for Robonix.
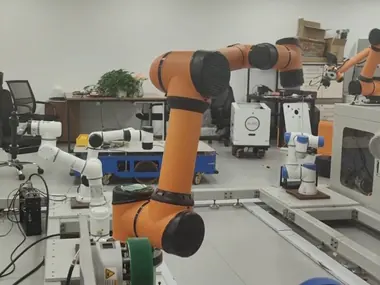
AUBO i5H deployment with an SDK arm primitive and optional wave skill.
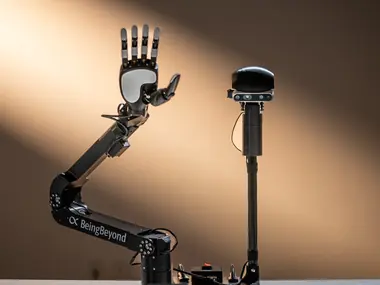
BeingBeyond D1 desktop robot deployment — dexterous-hand object pick/place skill.
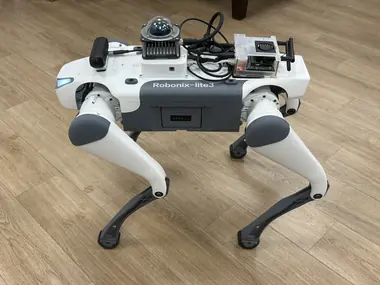
Minimal Robonix deployment for the Deep Robotics Lite3.
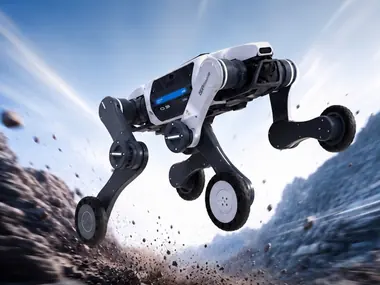
DeepRobotics Lynx S10 wheeled-quadruped deployment — native ROS 2 (drdds) chassis control.
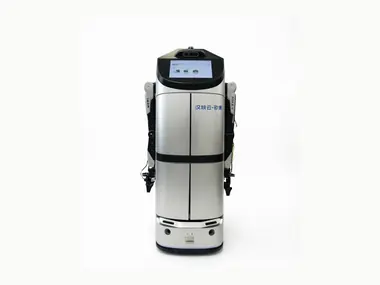
Robonix deploy manifest for the Hantewin Benben
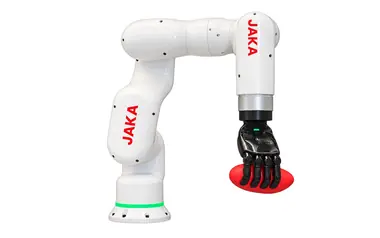
Robonix deployment for the JAKA Mini arm with a LinkerHand O6 dexterous hand.
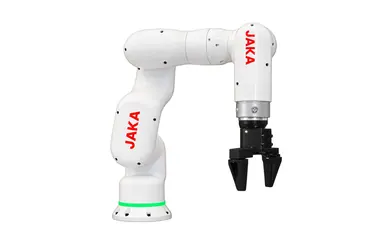
Robonix deployment for the JAKA Mini arm with TG-9801 gripper.
LinkerHand O6 standalone dexterous-hand deployment — finger dance and static gesture skill.
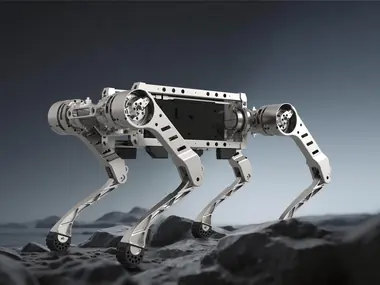
Dockerized MirrorMe BPX deployment with odometry, stand/sit, bounded move and velocity control.
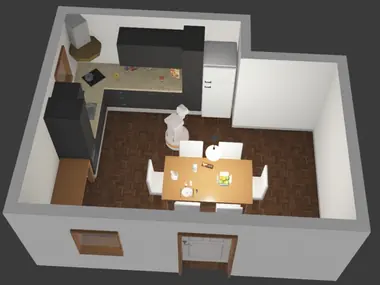
Webots TIAGo Lite simulation deployment — differential-drive base, head RGB-D camera, planar lidar, audio, mapping, navigation and exploration, with no robot hardware required.
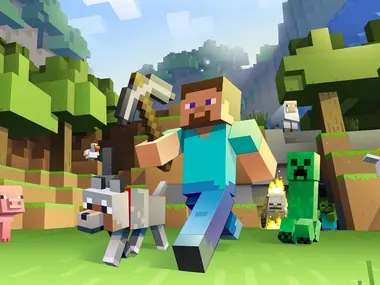
Robonix deployment for an autonomous Minecraft player.
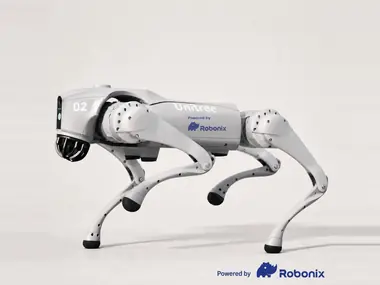
Safe Robonix deployment for Unitree Go2 with mapping, semantic navigation and read-only UI.
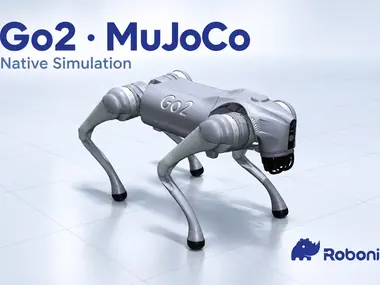
Web/native MuJoCo Go2 simulation with exploration and Scene semantic navigation.
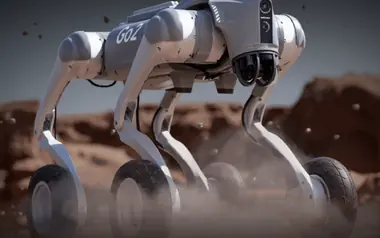
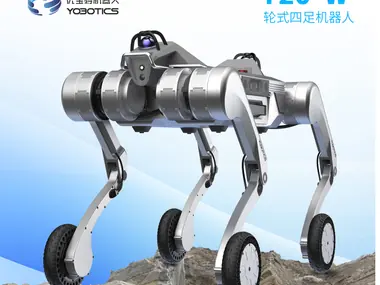
Native Robonix deployment for the Unitree Go2-W on Ubuntu 20.04, ROS 2 Foxy, and the onboard Orin NX.
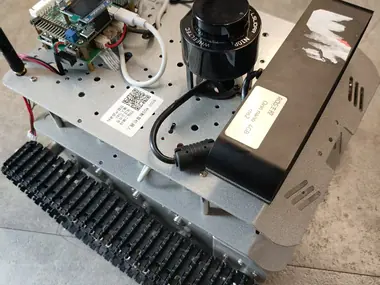
Wheeltec R550 mini_tank — 2D SLAM mapping deploy (N10P lidar + rtabmap).
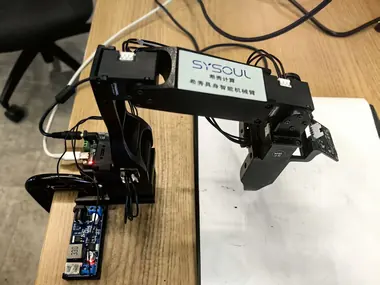
Roboarm LeRobot Koch 五自由度机械臂 Robonix 部署。
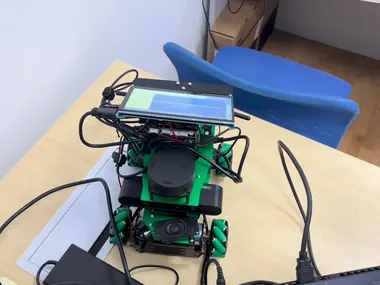
Guarded short-distance ROS 1 navigation for the Yahboom ROSMASTER X3.
Robonix robot deployment with Livox LiDAR, RealSense camera, chassis control, navigation, speech and scene understanding.
Nothing matches those filters.
Try a shorter search term, or clear the kind and tag filters.