AgileX Piper 6-DoF arm primitive with selectable ROS 2 and direct-SDK backends.
Packages
Reusable primitive, service and skill packages, indexed by capability, source and maintainer.
-
-
Piper arm URDF + robot_state_publisher wrapper (TF stand-in until soma ships).
-
Hand-eye calibration TF publisher (vendored easy_handeye2 0.5.0).
-
AgileX Ranger Mini chassis driver wrapper.
-
ALSA microphone capture and speaker playback primitive for Robonix.
-
Audio primitive that connects Robonix to robonix-client microphone and speaker devices.
-
D1 6-DOF arm primitive — absolute joint control (rad) + Cartesian move_pose via the SDK's arm-only IK.
-
D1 head RealSense D435i camera primitive — on-demand RGB + depth snapshots.
-
D1 dexterous-hand primitive — axis-level position control + speed/torque limits over CAN.
-
Deep Robotics Lite3 URDF and fixed sensor transform publisher.
-
Lite3 quadruped primitive with hardware and MuJoCo backends
-
Lynx S10 wide-angle RGB camera primitive — RTSP pull + live rgb stream + on-demand snapshot.
-
Lynx S10 3D lidar primitive — exposes the S10 native PointCloud2 stream.
-
Dynamic drone primitive — typed core (takeoff/land/hover/return-to-home/state) + generic invoke passthrough + list_capabilities dynamic discovery, so primitive capabilities extend dynamically as the APK updates
-
Intel RealSense D435i driver wrapper — declares RGB + depth + extrinsics contracts.
-
JAKA 6-DOF arm + TG-9801 gripper primitive (jkrc SDK over TCP).
-
JAKA 6-DOF arm + LinkerHand O6 dexterous hand primitive over one jkrc TCP session: arm contracts always, hand contracts in end_effector: hand mode (TG-9801 gripper mode retained).
-
LinkerHand O6 dexterous-hand primitive — axis-level position control + speed/torque limits over CAN.
-
LinkerHand O6 dexterous-hand primitive — joint-level position/speed/torque control over Modbus RTU (RS485), with an atlas-routed ROS 2 state stream.
-
Livox MID-360 IMU atlas wrapper — depends on mid360_lidar_rbnx.
-
Livox MID-360 lidar driver wrapper.
-
TODO: describe what this primitive package provides.
-
MirrorMe BPX odometry, stand/sit, bounded move and velocity provider with a Dockerized ROS 2 Humble runtime.
-
Orbbec RGBD camera primitive — multi-model wrapper over the vendored OrbbecSDK_ROS2 driver with config-selected launch file (Dabai DCW, Gemini 330-series), declaring rgb + depth + camera_info.
-
Orbbec Dabai DCW RGBD primitive — declares rgb + depth + camera_info.
-
Orbbec Gemini 330-series RGBD camera driver wrapper — declares RGB + depth + extrinsics contracts.
-
Body description for the Piper + adapter + LinkerHand O6 robot: URDF, meshes and a robot_state_publisher wrapper that owns the TF tree.
-
Publishes the Soma-owned URDF as the standard ROS 2 robot TF tree.
-
Minecraft Forge client primitive providing camera, chassis, perception, and Minecraft capabilities.
-
N10P Lidar driver for 2D SLAM mapping and navigation.
-
wheeltec r550_minitank chassis driver wrapper.
-
Guarded ROS1 navigation up to 0.80 m for Yahboom ROSMASTER X3.
-
Drone fire & smoke detection service -- pulls MJPEG frames from the DJI bridge APK, runs YOLO to detect flame/smoke; attaches the current GPS coordinates on a hit
-
Geometric grasp-pose estimator (gRPC).
-
SLAM mapping service. Algo + sensor inputs config-driven.
-
Memgraph MCP server — structured CKG memory (Scribe Mem) for the agent.
-
Experience-backed candidate action retrieval service for embodied models.
-
Memsearch MCP server — fact/preference memory for the agent.
-
Minecraft depth and exact-odometry 2D mapping service.
-
Minecraft occupancy-grid navigation service.
-
Nav2 service wrapper exposing service/navigation/* over gRPC.
-
Instruction-following navigation service — cloud S2 semantic latents plus edge S1 action generation with adaptive cloud-edge synchronization.
-
LLM-based object detection — atlas MCP service, drop-in replacement for yolo_world_rbnx.
-
PointCloud2 to LaserScan conversion service.
-
MoveIt + grasp executor (atlas-routed manipulation service).
-
Roboarm-style Python IK executor service for Piper manipulation.
-
Verify planar navigation results using Scene observations.
-
Voice interaction service (ASR + TTS + Dialog) under robonix/service/speech.
-
Lazy in-process VLA action verification service with Drafter verification and target-model fallback.
-
Generic visual result verification via a configured RGB camera.
-
Voiceprint service (CAM++ speaker identification) under robonix/service/voiceprint.
-
Manage asynchronous OpenVLA-OFT LoRA fine-tuning jobs.
-
Collect task-conditioned robot demonstrations into HDF5 episodes.
-
Convert robot HDF5 episodes into RLDS datasets.
-
Safely home and enable two AgileX Piper arms and grippers.
-
Execute a validated dual-Piper left-to-center-to-right transfer plan.
-
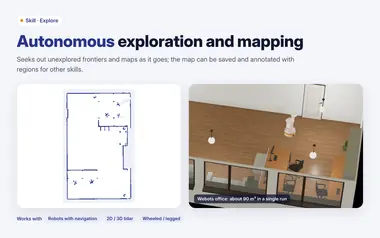
Frontier-based autonomous exploration skill.
-
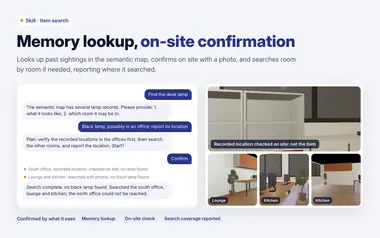
Find a lost item from what the robot remembers, then search room by room, after asking what it looks like.
-
Inspect the surroundings with a 360-degree camera sweep and review the latest observation.
-
Make the D1 dexterous hand perform a finger "dance" — a rhythmic open/close wiggle across all fingers for a given duration. A single MCP tool for the D1 hand.
-
Closed-loop visual navigation using InternVLA, a camera snapshot capability, and a chassis move capability.
-
JAKA Mini grab/release/home/place + camera-driven pick skill for both the TG-9801 gripper and the LinkerHand O6 hand bodies; includes fixed-pose pick-and-place (固定抓取).
-
Frontier-based exploration skill for the Minecraft example.
-
Multi-task OpenVLA-OFT manipulation skill for Robonix.
-
Flat-palm enveloping grasp skill (Piper + LinkerHand O6) — orchestrates object_detect + grasp_pose + execute_grasp and drives the hand.
-
Pick-up-a-named-object skill — orchestrates perception + manipulation services.
-
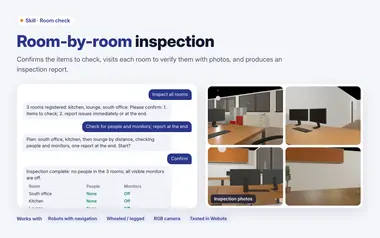
Check named rooms one by one and report what was seen, after asking what to check.
-
Seven independently registered Unitree Go2 action skills in one package, with randomized dancing and a shared runtime reusing eight physically validated routines.
-
Detect objects on the table (YOLO cubes, or open-vocabulary via a VLM), then grasp and place them (with optional grasp angle and gripper aperture) — MCP tools for the D1 dexterous hand.
-
VLA client skill — LLM-callable entry point for vision-language-action inference and JOINT-SPACE execution.
Nothing matches those filters.
Try a shorter search term, or clear the kind and tag filters.