robonix.robot.cyanroot.nianzhu_1y
robot
v0.1.0
Nianzhu-1Y is a mobile AI care robot for senior living and long-term care communities.
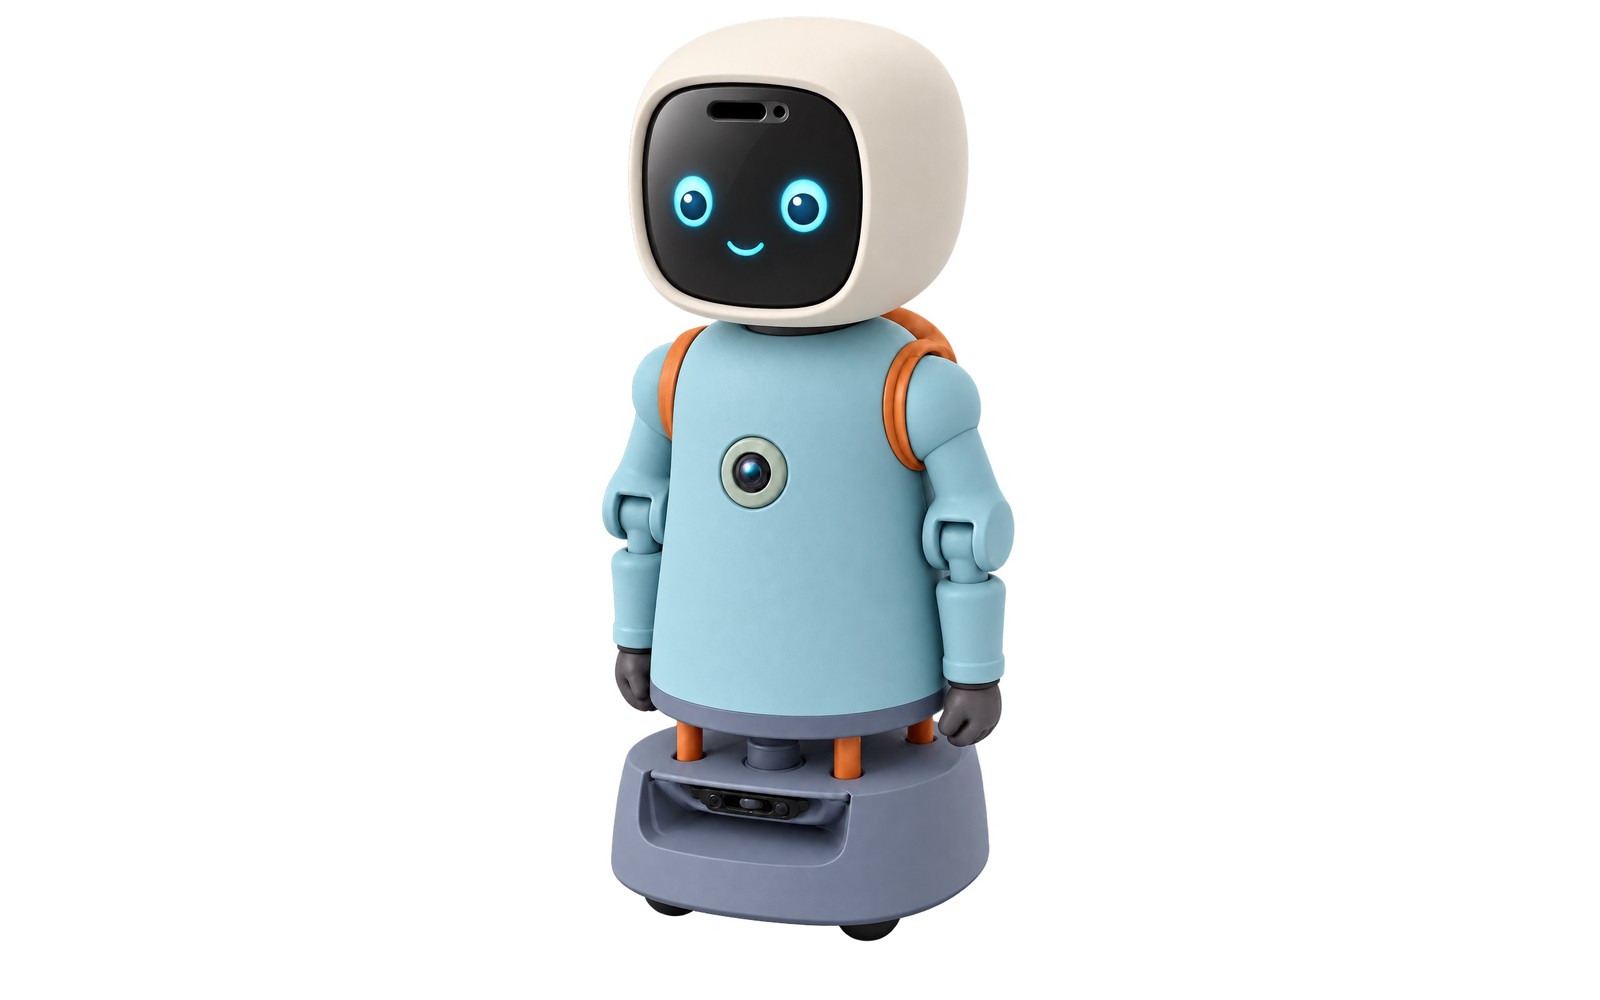
CyanRoot Nianzhu-1Y
Nianzhu-1Y is a mobile AI care robot for senior living and long-term care communities. Built on Robonix, it supports scheduled indoor rounds, spoken reminders, resident check-ins and staff follow-up.
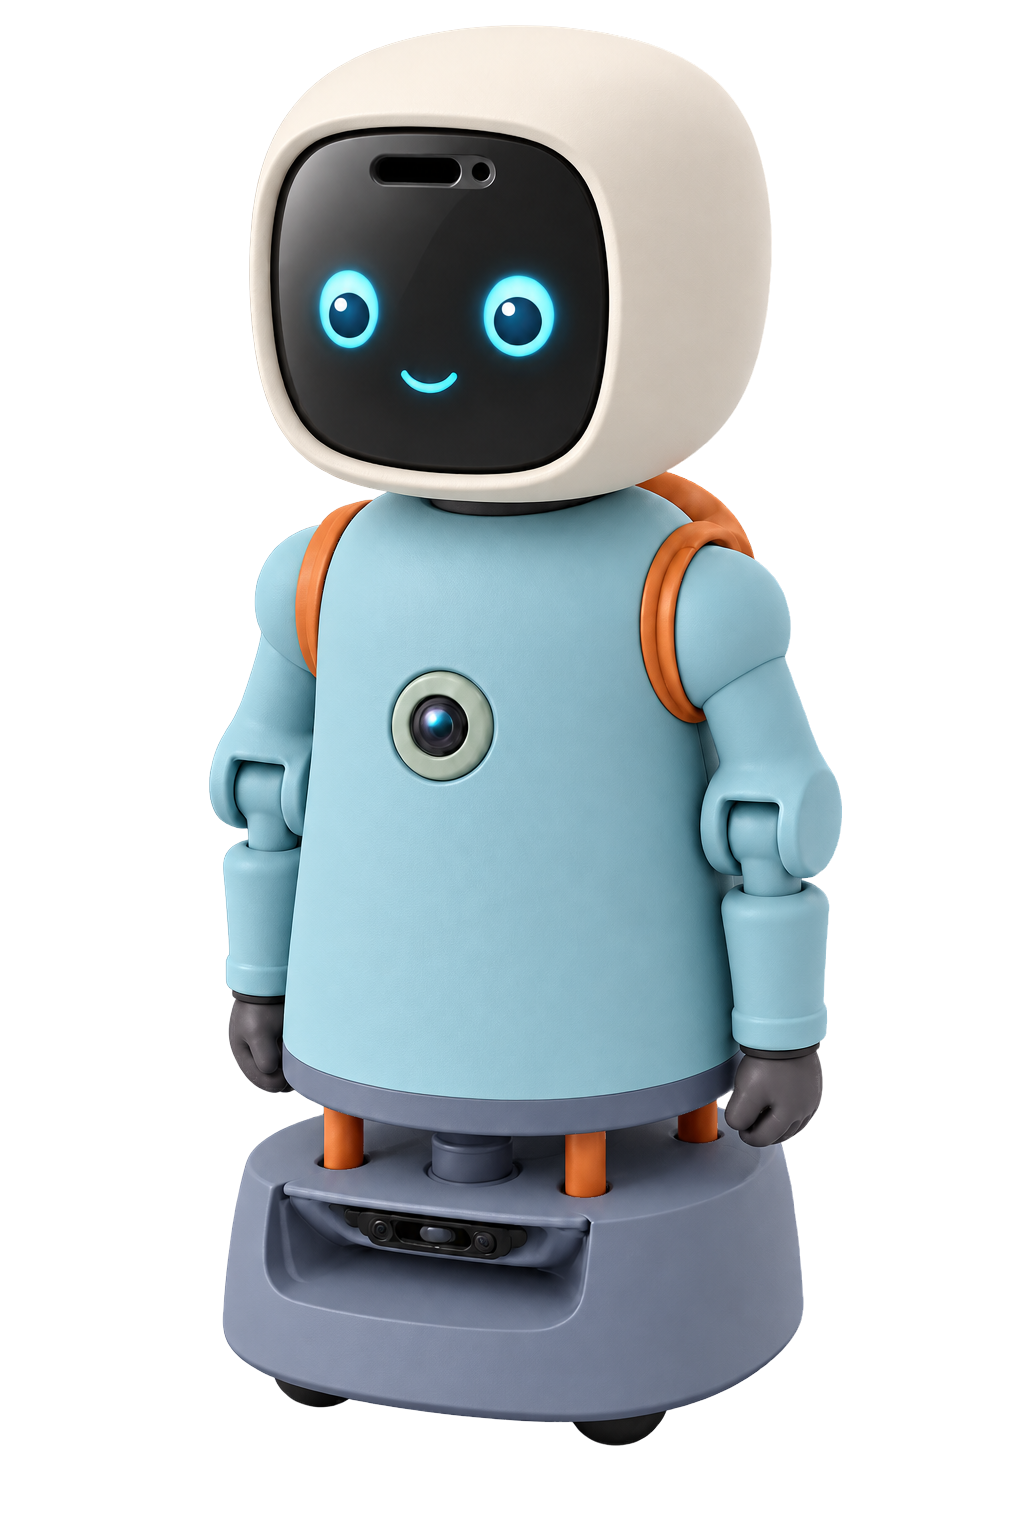
Product rendering.
At a glance
| The product | A care robot used in supervised pilots. Care workflows run on CyanRoot's care platform (staff dashboard, touchscreen content, family access). |
| This package | The open Robonix part of Nianzhu-1Y: a deploy manifest plus primitive and skill packages for the mobile base, board health, cameras, speaker direction, speech and web search. |
| Not in this package | The care platform, care workflows, conversation design and on-screen expressions. These stay with the product. |
| Status | Every package in this repository passes its unit tests on simulated devices and has started in a Robonix test stack. The robot as a whole has not been run from this package on hardware. See Verification. |
Care workflows (product)
These features are part of the Nianzhu-1Y product and are not provided by this package.
- Scheduled rounds and reminders. Staff set the location, time and message for a one-time or recurring task. At the designated point, Nianzhu-1Y can invite a resident to an activity, give a hydration reminder or ask a check-in question.
- Resident responses and staff follow-up. The robot logs the resident's response. Requests for help or check-ins without a confirmed response can be routed to care staff. Staff can see where and when the task took place, take over as needed and record the outcome.
- Conversation and family updates. Nianzhu-1Y supports spoken conversation on familiar topics and uses on-screen expressions. Where family access is enabled, authorized family members can view selected care summaries.
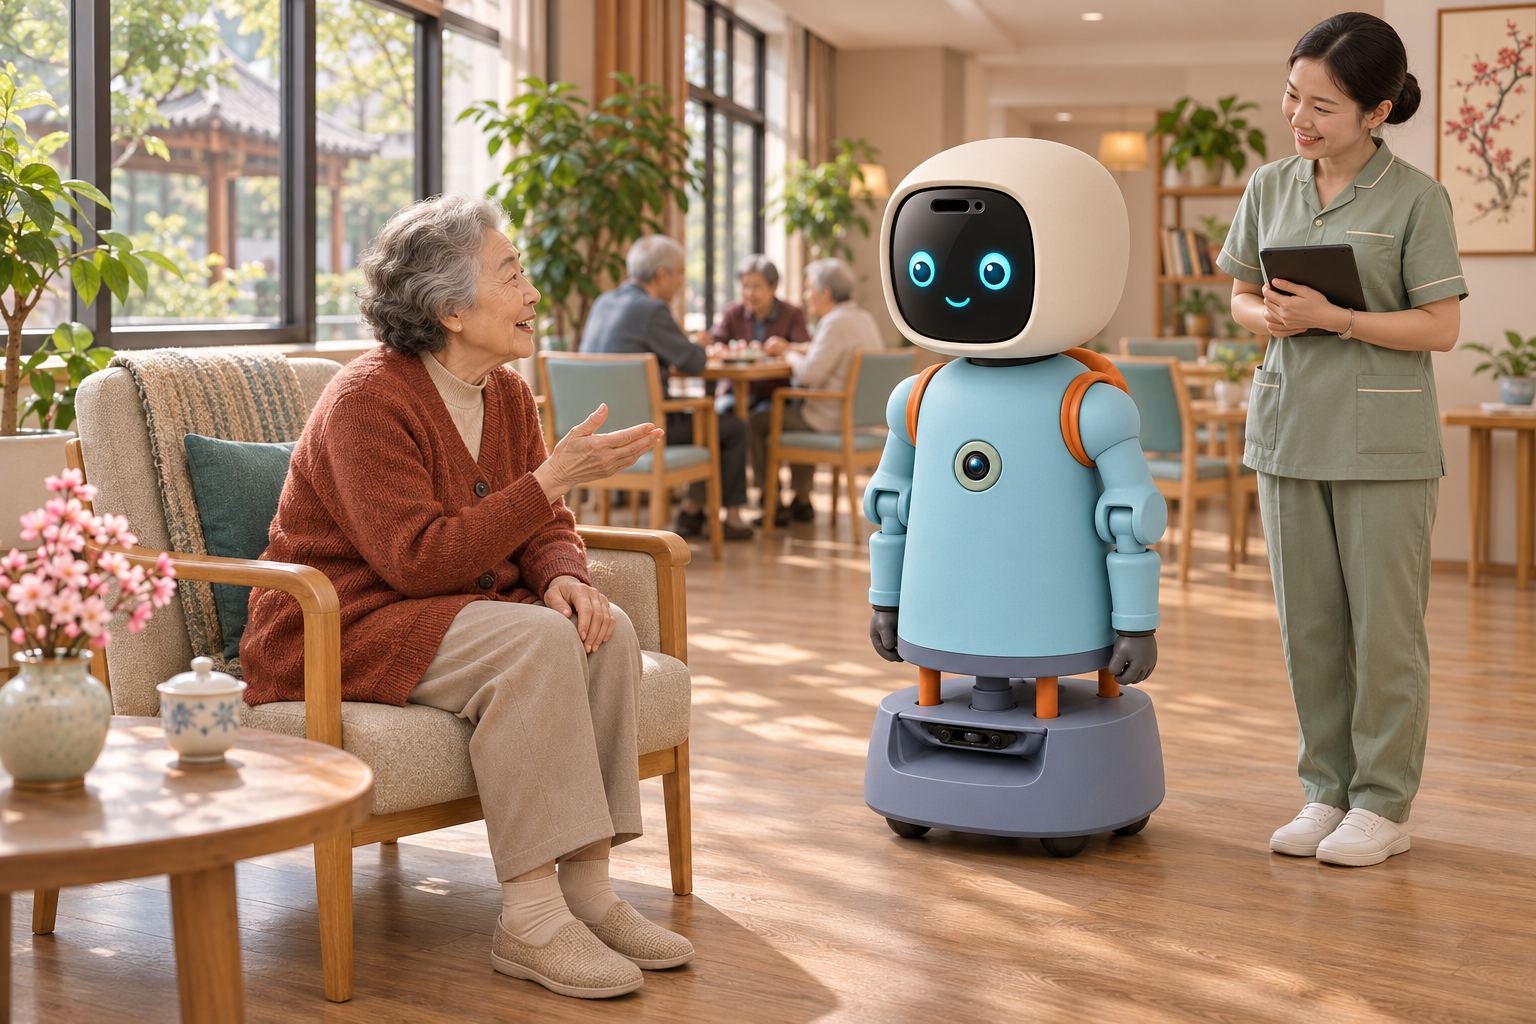
AI-generated illustration of an assisted resident check-in.
Life-story interviews in development
CyanRoot is developing guided life-story interviews for Nianzhu-1Y. A family photograph can prompt a conversation, and a companion service can help organize the resident's recollections into a draft for the family to review together.
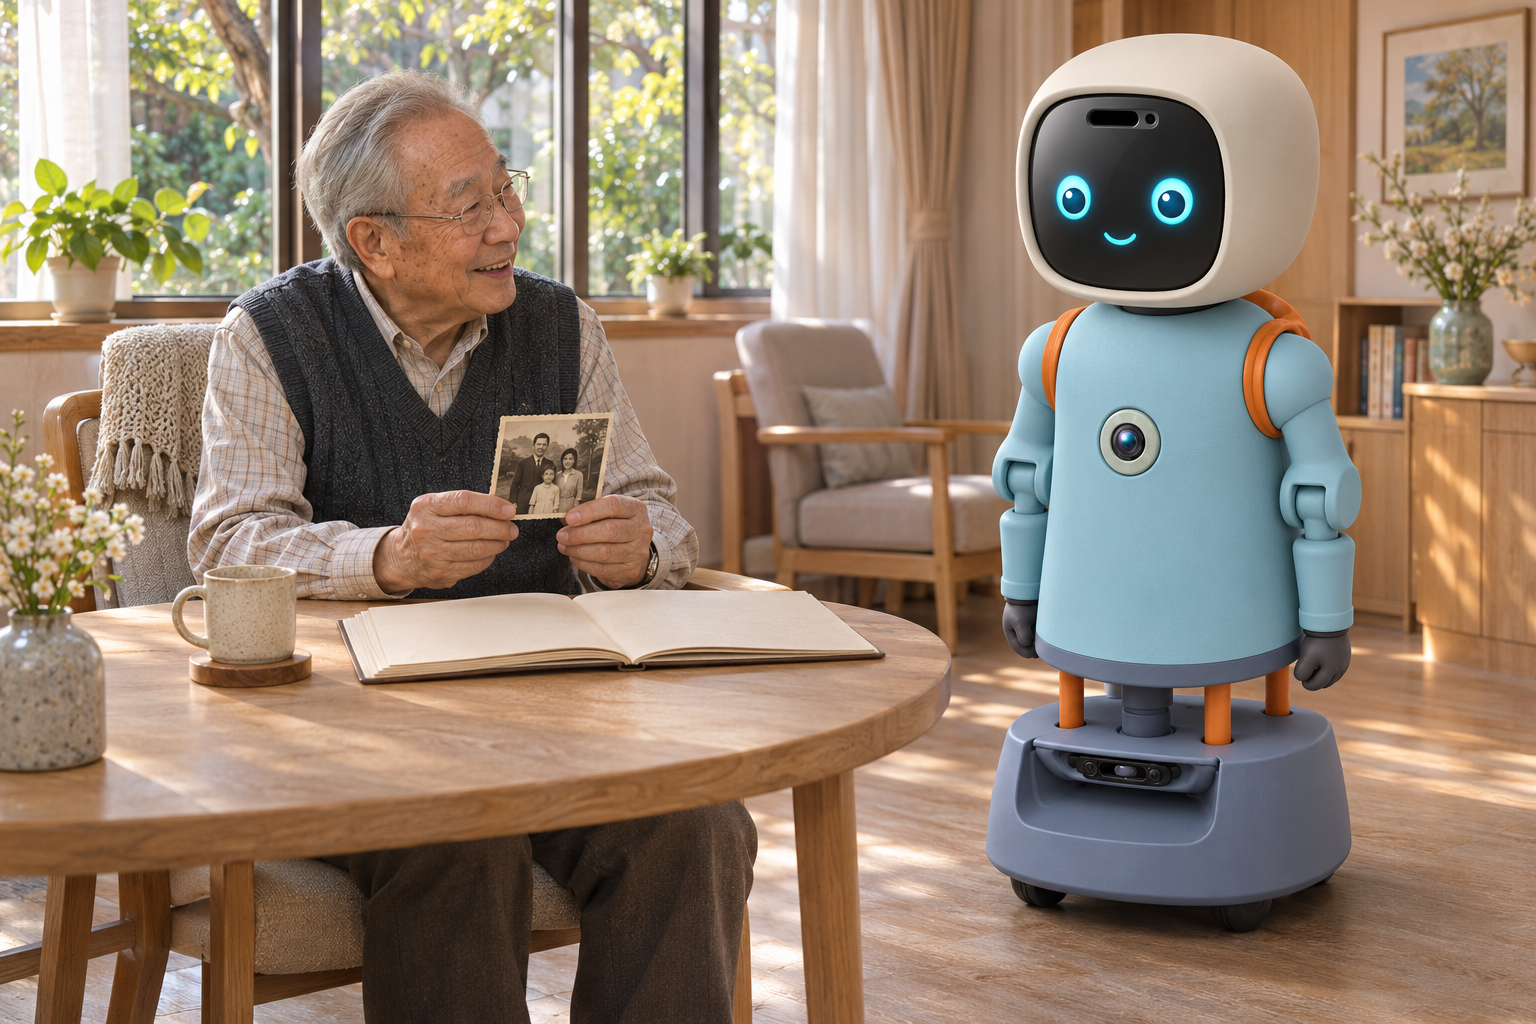
AI-generated concept illustration of a guided life-story interview.
Hardware
Nianzhu-1Y combines the CR-M1 robot body and a SLAMTEC Athena 2.0 mobile base with an automatic charging dock and a care staff dashboard.
| Component | Specification |
|---|---|
| Model | CR-1Y |
| Dimensions and weight | 1,255 × 640 × 530 mm (H × W × L). Approximately 40 kg. |
| Mobile base | SLAMTEC Athena 2.0. Chassis dimensions 429 × 460 × 237 mm. Chassis weight 22 kg. |
| Compute | RK3588 chassis controller and NVIDIA Jetson Orin Nano Super with 8 GB RAM and a 512 GB NVMe SSD. |
| Display | 10-inch square LCD touchscreen. |
| Audio | XMOS XVF3800 microphone array and dual speakers. |
| Navigation and docking sensors | RPLIDAR S2 LiDAR, Orbbec Gemini 335 depth camera, IMU and a QR-code camera for dock alignment. |
| Obstacle and edge sensing | Two ultrasonic sensors, a cliff-detection module and two collision sensors. |
| Battery | 18.2 Ah lithium-ion battery pack with a battery management system. |
| Charging | Automatic return to the charging dock. Dock input 100–240 VAC. Dock output 25.5 V DC at 10 A. |
| Runtime and charge time | Approximately 6–8 hours of operation and 4–5 hours to charge, depending on site configuration. |
| Connectivity | 2.4/5 GHz Wi-Fi, two Gigabit Ethernet (RJ45) ports and optional 4G. |
| Travel speed and thresholds | Up to 0.5 m/s in occupied areas. Plan routes for thresholds of 10 mm or less. The stated upper limit is 15 mm. |
| Operating environment | Hard, level, dry indoor flooring. 0–40 °C and 20–90% relative humidity. |
| Mapping | Up to 500 × 500 m at 5 cm map resolution or 350 × 350 m at 1.5 cm resolution. |
Robonix integration
Capabilities
| Hardware or service | Provider | Package | Exposed capability |
|---|---|---|---|
| Mobile base | chassis |
./primitives/chassis_sdk (vendor C++ SDK) or ./primitives/chassis_ros2 (vendor ROS 2 node) |
Relative moves, continuous Twist commands, odometry, LiDAR scans, IMU, base health; navigation, speed limits and maps handled by the base itself |
| Jetson Orin Nano | board_health |
./primitives/jetson_health |
Board temperatures and power-rail readings (Robonix health state and stream) |
| Gemini 335 depth camera | front_camera |
syswonder/primitive-orbbec-camera |
RGB, depth, extrinsics, snapshots |
| USB camera | usb_camera |
./primitives/uvc_camera |
RGB stream and snapshots; the device opens only while someone is using it |
| XVF3800 microphone array | voice_direction |
./primitives/xvf3800_doa |
Talker direction and voice energy, read-only |
| Speakers and microphones | audio |
syswonder/primitive-audio-driver-rbnx |
Audio input and output |
| Body model | robot_description |
syswonder/primitive-robot-description-rbnx |
Robot TF tree from the Soma body description |
| Speech | speech |
Robonix speech service, Tencent Cloud backend | Speech recognition, speech synthesis, dialog |
| Memory | memory |
Robonix memory service | Long-term memory for the agent |
| Web search | web_search |
./skills/web_search |
A web search tool for current information, through the DeepSeek Search API |
The preview includes two alternative Slamware chassis integrations. Choose one with the manifest: robonix_manifest.yaml (C++ SDK) or robonix_manifest.ros2.yaml (ROS 2 node).
Architecture
+--------------------------- Nianzhu-1Y ---------------------------+
|                                                                  |
|  +-- Robonix core --------------------------------------------+  |
|  | Pilot  Executor  Atlas  Soma  Liaison  Vitals              |  |
|  +------------------------------------------------------------+  |
|                                                                  |
|  +-- Skills ----------+ +-- Services -------------------------+  |
|  | web_search *       | | speech  memory  (come with Robonix) |  |
|  +--------------------+ +-------------------------------------+  |
|                                                                  |
|  +-- Primitives: one per piece of hardware -------------------+  |
|  | chassis *           mobile base                            |  |
|  | front_camera        Gemini 335 depth camera                |  |
|  | usb_camera *        USB camera                             |  |
|  | voice_direction *   XVF3800 microphone array               |  |
|  | audio               microphones and speakers               |  |
|  | board_health *      Jetson Orin Nano                       |  |
|  | robot_description   body model                             |  |
|  +------------------------------------------------------------+  |
|                                                                  |
+------------------------------------------------------------------+
* in this repository; the others are published Robonix packages
The Robonix core calls skills and services, and reaches the hardware only through primitives. speech and memory come with Robonix. Each package marked * is based on the source commit listed below. Local packaging changes add explicit transports, configuration specifications and executable script modes; see the package review.
Package sources
| Directory | Source commit |
|---|---|
primitives/chassis_sdk |
ffa2de74a8ad7280fb93e284a5149345b8f1f6a9 |
primitives/chassis_ros2 |
27775b03e2a564c2a433c9f779c812d6f9106e64 |
primitives/jetson_health |
318a8b4febd31859152871c997b600a3a6ce667d |
primitives/uvc_camera |
19b96b2264eaa2b04645b800e85e7e02c96567fc |
primitives/xvf3800_doa |
ecbdbfec2d4ea041a88141934a8c968e00e697a7 |
skills/web_search |
6bbdcbe3cb8089f385047d28289df0b08fa716b9 |
Verification
| Part | Level reached |
|---|---|
| Each package in this repository | Unit tests pass on simulated devices; started in a Robonix test stack on a virtual machine with simulated devices, all declared capabilities active |
Published packages (syswonder/...) and Robonix services |
As published by their authors |
| This robot as a whole, from this package | Not yet run on hardware |
Quick start
Requirements: Ubuntu 22.04 on aarch64 (Jetson) with ROS 2 Humble; Robonix installed (see syswonder/robonix); the base vendor's C++ SDK or ROS 2 node, which is not included here; keys for the language model, speech and web search.
This is a development preview. The supplied URDF, footprint and sensor installation transforms are illustrative and have not been calibrated for Nianzhu-1Y. The dimensions in the hardware table describe the product, while the model remains an example. Complete geometry calibration and hardware acceptance before deployment. Mapping and navigation are provided by the vendor base; this package does not use RTAB-Map or Nav2.
Install and register the Robonix source tree with rbnx setup /path/to/robonix, install uv, and source /opt/ros/humble/setup.bash. Obtain xvf_host separately from XMOS and put it on PATH. For the SDK backend, set SLAMWARE_SDK_DIR to the vendor SDK directory containing include/ and lib/; for ROS 2, source the vendor workspace or set SLAMWARE_ROS2_SDK for the interface build, and start the vendor node separately. Review each bundled package's config.spec for device and frame settings.
cp .env.example .env        # fill in the keys; never commit .env
set -a; source .env; set +a
rbnx build -f robonix_manifest.yaml
rbnx boot -f robonix_manifest.yaml        # base through the vendor C++ SDK
# or
rbnx build -f robonix_manifest.ros2.yaml
rbnx boot -f robonix_manifest.ros2.yaml   # base through the vendor ROS 2 node
Speed, distance and timeout defaults of the chassis primitive are conservative starting points; review them before running on real hardware.
Pilot deployment
The initial pilot uses supervised operation on a single mapped indoor floor. Before operation, the deployment team verifies doorways, turning space and Wi-Fi coverage, then sets task locations, exclusion zones and the charging dock position. The robot has a physical emergency-stop button. After an emergency stop is reset, care staff authorize movement to resume. Care staff retain responsibility for resident assessment and follow-up. Available features and access are agreed for each pilot.
For pilot inquiries, contact hi@cyanroot.com.