robonix.robot.dobot.nova5
robot
v0.1.0
Calibrated Nova5 wrist RGB box pickup, replacement and return home.
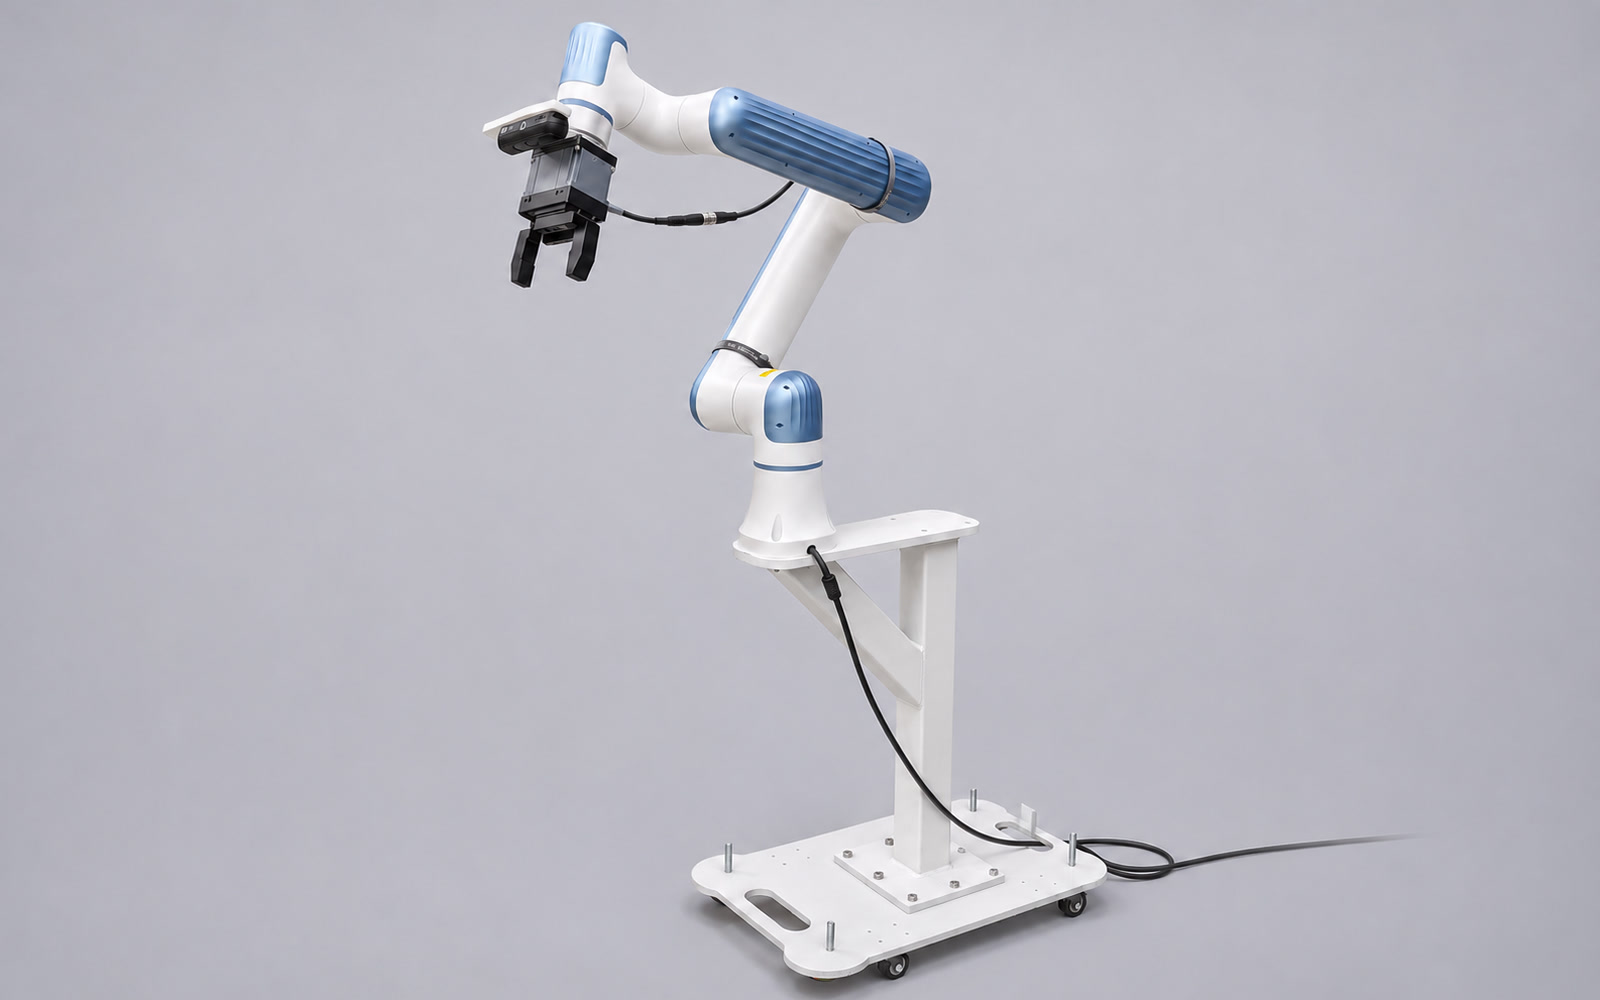
Nova5 RGB pick and return
Robonix Pilot observes the configured black box through a wrist RGB camera, selects separate pick, place and home capabilities to lift the box 30 mm, replace it, and return the arm home. Each action must succeed before the next one starts. The nova5_arm primitive owns the arm and gripper connections; the camera and skill use its capabilities. SDK commands use Tool0 flange MovL at 50 mm/s with a 174 mm TCP offset: the measured 165 mm gripper assembly plus the 9 mm white adapter plate. This does not guarantee constant fingertip speed during rotation. No depth image is used.
Install
Development and offline validation were performed on Ubuntu 22.04.5 LTS (x86_64, native Linux). The published deployment was validated on Nova5 hardware by completing the pick, place, and home sequence.
Use Linux, Python 3.12 with venv, Git, and the Robonix build dependencies. This deployment uses a contributor integration commit containing optional reasoning-effort forwarding and the Executor lifecycle Driver changes proposed in upstream PRs #321 and #322. It is not an official Robonix release.
git clone --branch nova5/core-integration-v0.1.0 https://github.com/mikequ95/robonix.git robonix-nova5
cd robonix-nova5
git checkout --detach 29b7459d149a4fc1c9315dcad4a817f8f14bebbe
git submodule update --init --recursive
make install
rbnx setup "$PWD"
Keep this source checkout available to rbnx. The five repositories are this deployment, nova5-support, primitive-dobot-nova5-arm-rbnx, primitive-dobot-nova5-camera-rbnx, and skill-nova5-pick-return-rbnx, all version 0.1.0. Their builds install declared dependencies, including the pinned official Dobot and Orbbec SDKs. The support, arm, camera, and skill repositories have published v0.1.0 tags.
Configure
The hardware is a Nova5, an Orbbec Gemini 336L wrist camera, and a PGI Modbus RTU gripper. Set up USB/serial permissions and controller networking; ports 29999 and 30004 must be reachable. Follow nova5-support's calibration instructions to obtain RGB intrinsics, the hand-eye transform, and the table plane. Existing calibration is valid only for the same unchanged mounting and base.
From this robot repository:
cp settings.example.json settings.json
Set the calibration configuration path, hardware and camera provider IDs, measured object height, allowed XY bounds, and home flange pose. Use allowed_xy_mm: [[x_min, x_max], [y_min, y_max]] and home_flange_mm_deg: [x, y, z, rx, ry, rz], in base/User0 coordinates with Tool0 and mm/degrees. Paths resolve relative to settings.json. Generate calibration files under calibration/, or set their actual location. The hardware, camera and skill must use the same calibration configuration. Keep device settings, calibration results and credentials out of Git.
Before executing a grasp, set motion.enabled=true, motion.speed_mm_s=50, and verified finite XYZ workspace bounds in that calibration configuration; see the skill configuration. The template deliberately disables motion. This deployment explicitly sets nova5_arm.config.enable_opening=true so the skill can release the box after placement; activation does not open the gripper. The 174 mm TCP already includes the adapter; do not add another 9 mm.
The URDF includes the nominal six-axis Dobot Nova5 model, the white adapter plate, and the TCP at 174 mm from the flange. Dobot meshes retain their MIT license. Arm joint limits are copied from upstream, including zero effort/velocity values; the SDK performs inverse kinematics and motion control.
The adapter is uniformly 9 mm thick. Its stem is 64 mm wide, with a 32 mm radius end centred on the flange; the distance from the round tip to the crossbar's near edge is 115 mm. The centred crossbar is 160 x 24 mm, giving an overall length of 139 mm. It extends along flange -X toward the camera. Mounting holes are not modelled.
The gripper is represented only by the tcp frame at xyz="0 0 0.174" relative to flange. The offset uses the measured 165 mm assembly length (including the black mounting plate) plus the 9 mm adapter. No gripper meshes or finger joints are distributed, so this URDF cannot model gripper collisions or contact. Verify the TCP against the actual mounting before motion.
The camera has an optical frame but no housing mesh. wrist_rgb_optical_fixed uses this installation's hand-eye calibration; update it from T_flange_camera after remounting (translation in metres, URDF RPY in radians). This transform is relative to the robot flange and must not receive another 9 mm offset.
Run
export NOVA5_SUPPORT_SOURCE='git+https://github.com/mikequ95/nova5-support.git@v0.1.0'
export NOVA5_HARDWARE_SOURCE='git+https://github.com/mikequ95/primitive-dobot-nova5-arm-rbnx.git@v0.1.0'
export NOVA5_CALIBRATION_CONFIG="$PWD/calibration/config.json"
export NOVA5_GRIPPER_PORT='/dev/serial/by-id/<gripper-serial-id>'
export NOVA5_SETTINGS="$PWD/settings.json"
export VLM_BASE_URL='https://your-openai-compatible-endpoint/v1'
read -rsp 'API key: ' VLM_API_KEY; echo
export VLM_API_KEY
export VLM_REASONING_EFFORT=high
rbnx build -f robonix_manifest.yaml
rbnx boot -f robonix_manifest.yaml --verbose
The source variables also accept absolute paths to local checkouts. Keep all three providers on this host; feedback windows use its monotonic clock. The model endpoint must support gpt-6-astra, images, tool calls, structured responses, and high reasoning effort.
Before first real motion, verify that an independent hardware emergency stop is functional. Before motion, the arm must be enabled and idle in TCP control mode with zero User0/Tool0 offsets. The gripper must be initialized, idle (state 1), in IO mode 0, with force 20%, speed 1%, and equal target/actual opening. Start with at least 200 mm TCP clearance above the table and a clear path to the box.
In another terminal using the same ROBONIX_HOME, check registration and observation:
rbnx caps -v
rbnx ask 'Only call nova5_wrist_rgb to capture one wrist RGB image. Do not invoke any motion or grasp skill.'
Then request one cycle:
rbnx ask 'Observe the black box on the checkerboard with the Nova5 wrist camera and read the skill instructions. If clearly visible, pick it up, put it back at its recorded position, and return the arm home using the available Nova5 capabilities. Wait for each action to complete before continuing. Report the final result; stop on any failure and do not retry motion.'
The three actions share a persistent task journal. pick leaves the object held, place releases it at the recorded position and retreats, and home returns the empty arm. A failed or canceled action prevents continuation even after restart. Inspect the hardware and reported log; follow the skill README for journal recovery only after manual physical recovery. Restarting does not release the gripper or move the arm. Stop with:
rbnx shutdown -f robonix_manifest.yaml
For local development, use an ignored robonix_manifest.local.yaml copy: replace each package's url and branch with a path to its absolute source directory, then pass that manifest to rbnx build and rbnx boot.