robonix.robot.jaka.mini_with_tg9801_gripper
robot
v0.1.0
Robonix deployment for the JAKA Mini arm with TG-9801 gripper.
robot-jaka-mini_with_tg9801_gripper — JAKA Mini Robonix deployment
Robonix deployment for the fixed-base JAKA Mini 6-DOF arm with a TG-9801 adaptive gripper (end RS485). The arm is driven by the primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx package over TCP to the controller (jkrc SDK).
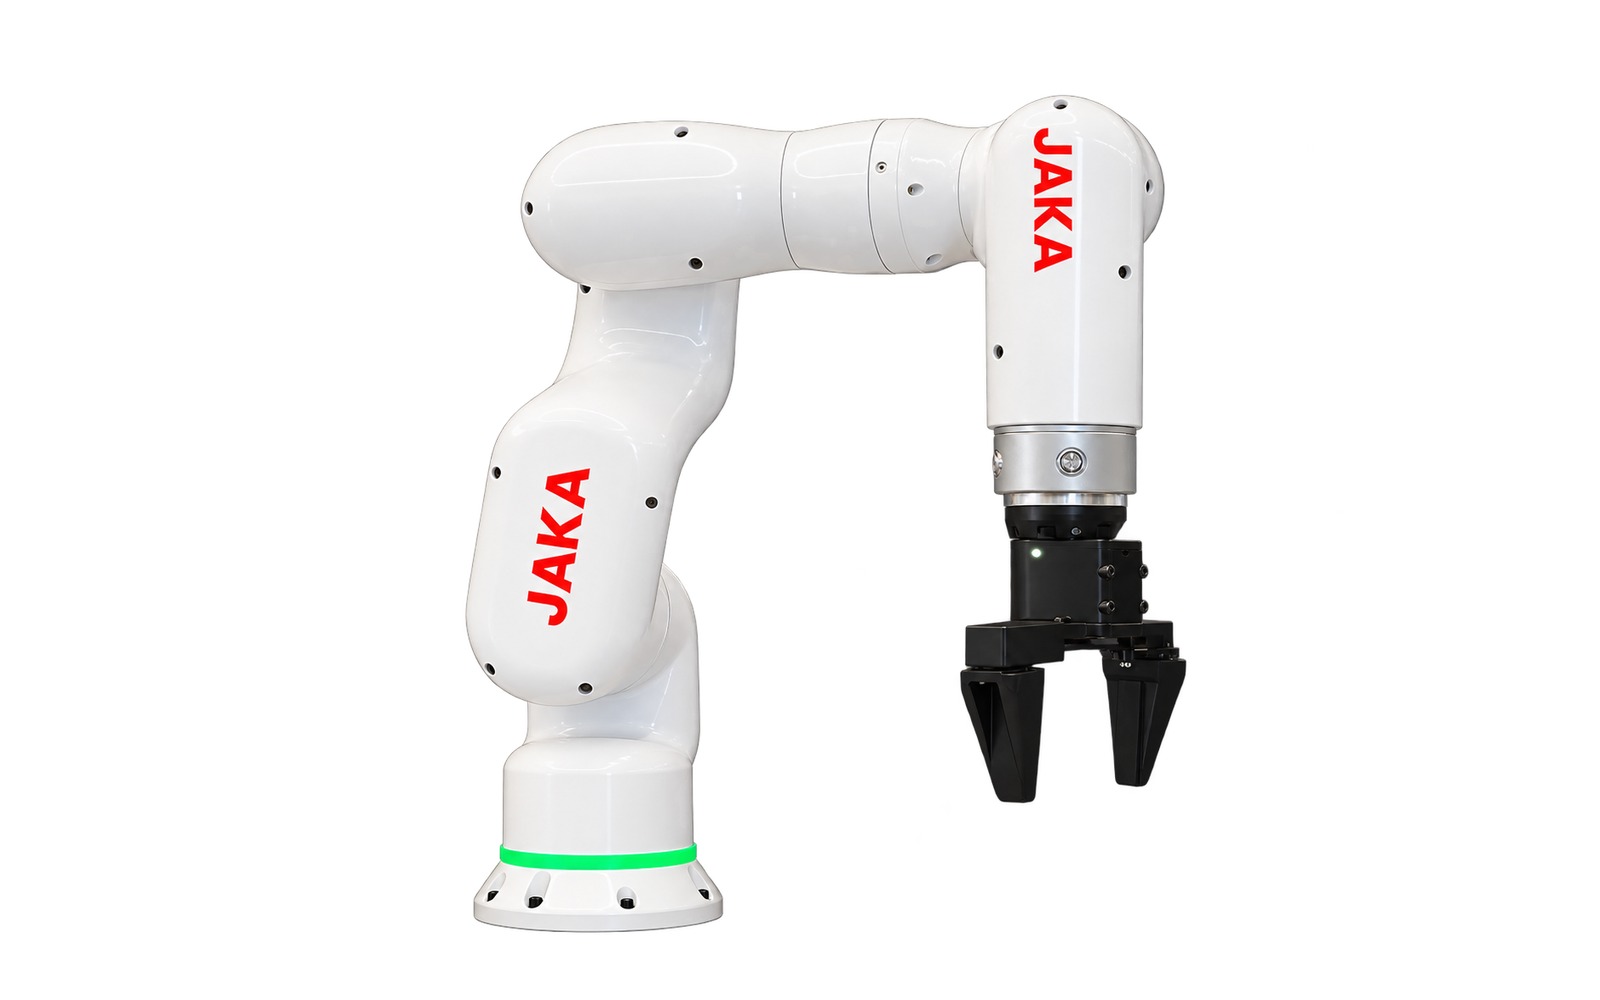
Hardware & platform
| item | value |
|---|---|
| arm | JAKA Mini, controller at 10.5.5.100 (config jaka_arm.ip) |
| gripper | TG-9801, RS485 via controller end channel |
| camera | Orbbec Gemini 336L (USB 2bc5:0807), overhead/fixed — RGBD, 1280×720 |
| platform | Jetson Orin, JetPack 6 (aarch64), ROS 2 Humble + rmw_zenoh_cpp |
| base | fixed (no mobile base, no navigation) |
Packages
The committed manifest references all packages by url: — catalog-resolvable
for the package site; rbnx boot fetches them into rbnx-boot/cache/:
| package | repo | role |
|---|---|---|
jaka_arm |
syswonder/primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx | arm primitive — robonix/primitive/arm/* over jkrc TCP |
orbbec_camera |
syswonder/primitive-orbbec-camera-rbnx | Orbbec camera primitive — robonix/primitive/camera/{rgb,depth,camera_info} (Gemini 336L via gemini_330_series.launch.py) |
jaka |
syswonder/skill-jaka-grasp-rbnx | grab/release/home/place + camera-driven pick skill (fixed-pose jaka_fixed_grasp, 固定抓取) — robonix/skill/jaka/* |
On the deploy machine, a gitignored robonix_manifest.local.yaml (same
content, path: instead of url: for the three packages above) makes
build.sh / start.sh build and boot the sibling checkouts
(../primitive-*-rbnx, ../skill-jaka-grasp-rbnx) directly — no GitHub fetch,
unpushed local edits take effect. robot_description has no local checkout
and stays url: (built from rbnx-boot/cache/; refresh with rbnx update).
Pick skill (camera-driven grasp)
jaka_pick locates a named object and grasps it: resolve camera/rgb → grab a
frame → detect → a calibrated 2D hand-eye homography maps the bbox centre
to arm base_link XY → grasp at (x, y, desktop_height) with a
vertical-down orientation. It reuses the same grasp segment as grab.
Two detection backends (detect_scheme in the skill config):
yolo(deploy default): in-process yolo11-obb — the fruit model (carrot/potato/tomato) reused from the agilex deploy atrobot-agilex-robonix/host-services/yolo/weights/best.pt(point theYOLO_MODEL_PATHenv var at it — the manifest forwards it toyolo_model_path; the skill interpreter has CUDA torch + ultralytics). Two-frame consistency filters flicker; Chinese phrasing maps to class names viayolo_class_aliases(胡萝卜→carrot …); the OBB rotation aligns the gripper yaw to the object's long edge (rz = grasp_yaw_offset_deg - yaw, default -90 = this arm's tuned value — adjust by ±90 if the fingers land off-axis).vlm: open-vocabulary multimodal detection (pixel bbox, no rotation → fixedgrasp_rpy).
Calibration is required and on-site. pick is unavailable until you set,
in robonix_manifest.yaml's skill: - name: jaka config block:
- homography_matrix — 3×3 pixel→base_link, calibrated at 1280×720 (same kind
of matrix as agilex's grasp_pose);
- the scheme's detector: the YOLO_MODEL_PATH env var (weights file,
exported like the VLM vars — e.g. in .vlmkey) or
vlm_base_url / vlm_api_key / vlm_model (multimodal endpoint);
- desktop_height — the table height in base_link (grasp z).
Until then pick returns a clear error; grab / release are unaffected.
Calibration
jaka_pick's homography_matrix is measured on site with the in-tree bench
under tools/calibration/ — a cv2-GUI tool (served as a browser page on
headless machines) for this JAKA Mini + Gemini 336L pair. The arm side reuses
primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx's
JakaDriver (probed from the sibling checkout or rbnx-boot/cache/), so the
tool ships no jkrc/gripper code and no SDK binaries; the intrinsics
(camera_matrix / dist_coeffs) ship as data in
tools/calibration/intrinsics-data/.
Run it with robonix stopped (the camera and the controller are single-owner), workspace clear, estop at hand:
bash tools/calibration/setup_venv.sh
cd tools/calibration && .venv/bin/python calibrate_handeye_2d.py            # default: calibrate
cd tools/calibration && .venv/bin/python calibrate_handeye_2d.py --mode test
The tool prints the fitted matrix as ready-to-paste YAML rows; hand-copy it
into homography_matrix in both robonix_manifest.yaml and
robonix_manifest.local.yaml. desktop_height is not produced by the tool.
The matrix is only valid at 1280×720 on undistorted frames — the tool pins
the stream and warns loudly on any fallback. Full flow and gotchas:
tools/calibration/README.md (Chinese).
Estop recovery
After the emergency stop is released (pendant knob pulled up; the controller is
usually powered off), tools/jaka_estop_recover.py resets it over raw jkrc:
clear error → power on → enable → confirmation → slow move to Home (all-zeros)
→ disable and power off. It reuses the calibration bench's plumbing (arm package
probe, arm_port from tools/calibration/config.yaml, the Python 3.10 venv) and
bypasses the runtime's motion_enabled gate — run it with robonix stopped:
tools/calibration/.venv/bin/python tools/jaka_estop_recover.py
URDF
urdf/robot.urdf is the JAKA app export of the real JAKA Mini
(with meshes/). It is consumed by Soma (urdf.path in soma.yaml),
which serves the raw XML to robot_description via get_urdf.
The export was post-processed for this deployment: the 6 arm joints were
renamed link_002_joint..link_007_joint → joint_1..joint_6 so
robot_state_publisher matches the joint_states names published by the
jaka_arm provider. If the URDF is re-exported from the JAKA app, re-apply
this rename (see the note in soma.yaml). The two gripper finger joints
(link_008_joint/link_009_joint) are kept as exported; the provider
publishes a single gripper_joint value.
Prerequisites
- Robonix tooling:
make installfrom a clonedsyswonder/robonixcheckout, thenrbnx setup <robonix source dir>. sudo apt install ros-humble-rclpy ros-humble-rmw-zenoh-cpp ros-humble-nav-msgs ros-humble-sensor-msgs(nav-msgs/sensor-msgs feed the Soma runtime reader — see theruntime_reader_commandcomment in the manifest)- Primitive package built:
bash build.sh(builds the sibling checkouts via the local manifest; a first build on a fresh clone fetches the url-based packages intorbnx-boot/cache/)
Build
bash build.sh
build.sh is the canonical entry: it prepares the deploy venv, then builds
every package declared in the manifest (the local path: variant when
present, else the committed url: one) with --no-update-check so builds
stay offline. robot_description is fetched from the package catalog into
rbnx-boot/cache/ when missing.
Camera build note (native): the Orbbec driver (
../primitive-orbbec-camera-rbnx) colcon-builds the vendoredOrbbecSDK_ROS2, which needs ROS 2 C++ deps (rclcpp,image_transport,cv_bridge,camera_info_manager,tf2_ros, …) absent from this Jetson's minimal/opt/ros/humble. Install them once per machine (needs sudo):bash ../primitive-orbbec-camera-rbnx/scripts/install_deps.shThe camera
build.shchecks for these and fails fast with this pointer if they're missing. The arm-only stack builds fine without them (the camera primitive is only needed forpick).
Boot
# standard entry — committed url manifest, packages from rbnx-boot/cache/
rbnx boot

# offline / pinned cache: skip the pre-boot per-package `git fetch`
rbnx boot --no-update-check

# after estop verification and single-joint tests, enable motion in
# robonix_manifest.yaml: jaka_arm.config.motion_enabled: true
Motion commands stay rejected while motion_enabled: false (safety gate,
see ../primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx/config.spec).
Bare rbnx boot resolves every package to its rbnx-boot/cache/ clone
(no sibling checkouts needed); the jkrc SDK ships inside the arm package
(Apache-2.0), so no manual copy is needed. Per-machine prerequisites:
.vlmkeyvars in the booting shell —bash start.shsources them, bare boot cannot (this machine's~/.zshrcdoes).- on a fresh machine,
bash build.shonce before the first boot — it prepares the deploy venv and the codegen interpreter the packages' builds need (rbnx boot's inline-build fallback does not set it).
The pre-boot freshness check only reports; it never pulls. When it marks
a provider behind, run rbnx update (needs network) before booting.
The manifest's env.PATH expands ${PWD}/.venv/bin — the venv built by
build.sh that gives the robot_description provider a new enough grpcio
for its generated bindings; boot from this directory.
Development against unpushed sibling edits uses the gitignored
robonix_manifest.local.yaml (path: entries): build.sh and start.sh
prefer it (start.sh also sources ROS + .vlmkey and owns the
zenoh-router lifecycle). Push, then rbnx update, to give bare boot the
same code.
Acceptance record
| stage | command | expected |
|---|---|---|
| static | rbnx validate ../primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx && bash build.sh |
all packages built |
| unit | cd ../primitive-jaka-mini_with_tg9801_gripper-arm_gripper-rbnx && .venv/bin/python -m unittest jaka_arm.tests.test_driver |
8/8 OK |
| read-only arm | bash start.sh |
joint_states/end_pose stream; gripper_joint open/unknown sane (~0.5 Hz refresh) |
| single joint | motion_enabled: true, ros2 topic pub /jaka/joint_command small delta |
joints follow, limits hold, estop works |
| gripper | gripper_joint close/open | soma reports open / holding |
| camera | bash start.sh, rbnx caps -v |
orbbec_camera ACTIVE; camera/rgb streams 1280×720 |
| pick (dry) | set VLM + homography, jaka_pick {object} before enabling motion |
detect + geometry resolve; motion times out with motion_enabled hint |
| pick (live) | motion_enabled: true, calibrated | arm descends on the detected object, closes, lifts |
| shutdown | Ctrl-C | gripper opens, arm returns to shutdown_home_joints (all-zeros), motion stops, arm powered off, logs clean |
Fill in the robot revision, Robonix commit (git -C <robonix> rev-parse HEAD)
and measured gripper open reading here after acceptance.