robonix.robot.unitree.go2w
robot
v0.1.0
Native Robonix deployment for the Unitree Go2-W on Ubuntu 20.04, ROS 2 Foxy, and the onboard Orin NX.
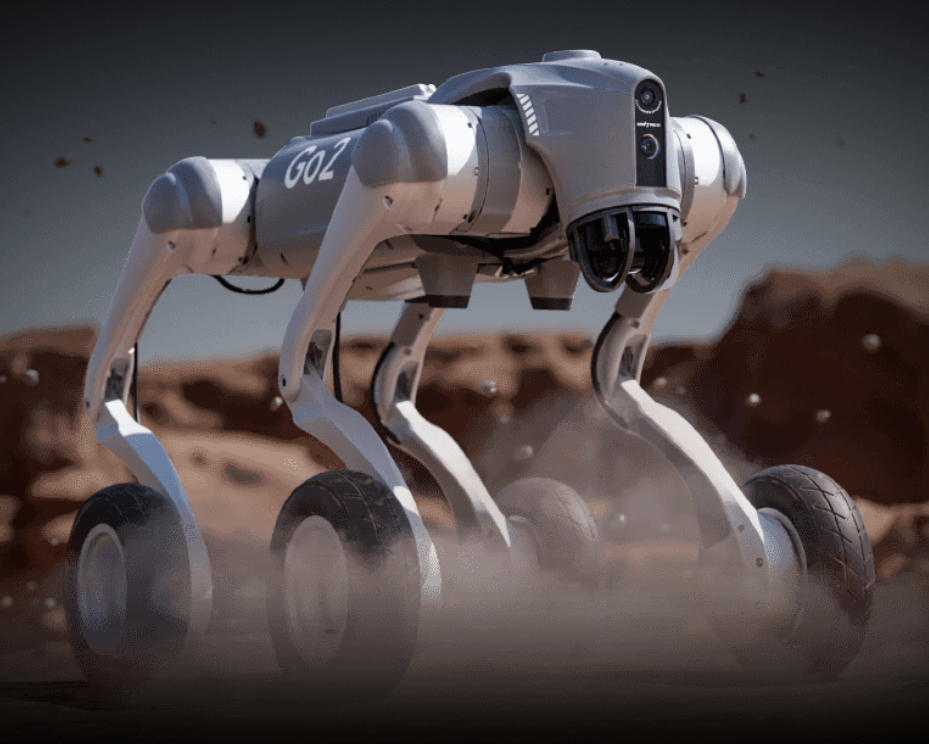
Robonix deployment for the Unitree Go2-W
This repository is the robot deployment for a Unitree Go2-W running Ubuntu
20.04, ROS 2 Foxy, and the onboard Orin NX. Its catalog name is
robonix.robot.unitree.go2w.
The launch manifest is the repository-root robonix_manifest.yaml.
native/robonix_manifest.yaml points at that same file.
python3 native/fetch_go2w_model.py
bash build.sh
bash native/build-motion.sh
bash native/validate.sh
bash start.sh
build.sh also fetches the pinned audio bridge and ROS Foxy sensor_msgs_py.
The Go2-W model download above has to happen first; the build stops if that
model is missing. See docs/DEPLOYMENT.md.
native/build-motion.sh separately compiles the SDK daemon and guarded ROS
adapter required by the chassis enable primitive. It only builds artifacts
and runs offline tests; it does not enable the chassis or execute a posture.
build.sh and start.sh use the native profile. It does not start a
container and does not change the host network. Motion stays disabled until
an operator enables it explicitly. See native/README.md
for sensor topics, process layout, and service commands.