robonix.robot.unitree.r1
robot
v0.1.0
Onboard Unitree R1 EDU deployment with body description, state, perception, and walking plus dual-arm control through the official sport mode.
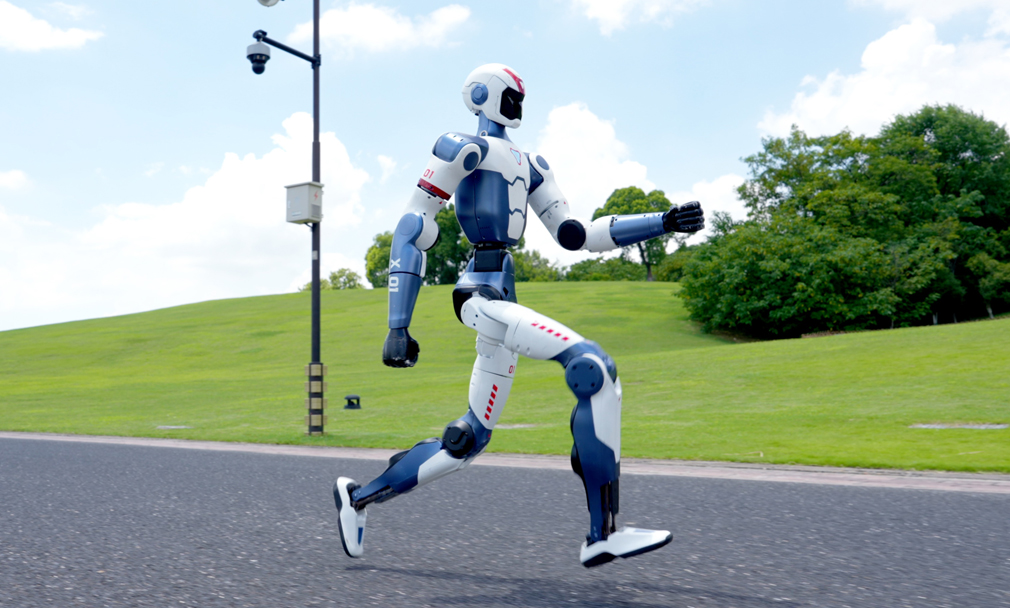
Unitree R1 EDU
Robonix deployment repository. Catalog name: robonix.robot.unitree.r1.
The deployment includes the body description, state, health, RGB, depth, IMU and audio, plus walking and dual-arm control through Unitree's official sport controller. Speech and the visual action decider start with the full manifest. Primitives and services live in this repository and are referenced by relative path.
Maintainer: Zhenyu Zhang \<768726812@qq.com>
Prepare the Robonix source tree, wheels, toolchains, and speech models before the first build. The layout and checksums are in INSTALL.md. Licenses for vendored files are in NOTICE.
Start
Two entries are available. They do not start the same processes.
rbnx boot starts only the providers and services named in the manifest: Atlas, Soma, Vitals, Pilot, the hardware primitives, speech, and the visual action decider. It does not start the Unitree depth receiver, the map service, or the web client. rbnx must already be on PATH, and the packages must already be built.
source scripts/env.sh
rbnx boot -f robonix_manifest.yaml --no-update-check
scripts/env.sh exports ROBONIX_DEPLOY_DIR. Thresholds, the wake-word model, and record directories in the manifest expand from that directory. For chat, export VLM_BASE_URL, VLM_API_KEY, and VLM_MODEL before this command, or accept the defaults documented in INSTALL.md. The key is not stored in the manifest.
scripts/02_start.sh is the onboard helper. It also starts the depth receiver, the map service on port 50107, and the web client on http://127.0.0.1:7860/. It expects the workspace in INSTALL.md, Stereo patch PC1 with video_hub off, and an OpenAI-compatible service at VLM_BASE_URL when chat is required. Store a key with bash scripts/vlm_key.sh set deepseek.
bash scripts/01_build.sh
bash scripts/02_start.sh
bash scripts/03_stop.sh
The read-only sensor deployment omits the chassis, arms, audio, and dialogue. It does not start the web client:
bash scripts/start_sensors.sh
bash scripts/stop_sensors.sh
robonix_manifest.r1-native.yaml is a symlink to the root manifest, so existing boot commands that use that filename keep working.
Other manifests
These files are local launch profiles. The package catalog indexes only robonix_manifest.yaml.
| File | Use |
|---|---|
robonix_manifest.r1-native-sensors.yaml |
State, health, RGB, depth and IMU |
robonix_manifest.r1-native-state.yaml |
Atlas, Soma and read-only state |
robonix_manifest.state-only.yaml |
State-path check on a workstation |
robonix_manifest.pc-readonly.yaml |
Read-only state, health and camera on a workstation NIC |
Layout
robot-unitree-r1/
├── robonix_manifest.yaml          # catalog-indexed deployment
├── soma.yaml                      # body, components and exports
├── urdf/                          # official URDF and meshes, BSD-3-Clause
├── config/                        # Vitals thresholds and approximate camera parameters
├── primitives/                    # chassis, arms, sensors and audio
├── services/                      # speech and visual action decider
├── map_service/                   # onboard occupancy grid
└── scripts/
audio_client_bridge is included in this tree. It corresponds to the published package robonix.primitive.audio.client_bridge. The URDF comes from unitreerobotics/unitree_ros robots/r1_description; see urdf/LICENSE.unitree. Mesh paths and filenames stay as upstream published them. The only addition is a zero-offset base_link.
Forward and backward walking, and both wrist joints, have on-robot records. Turning, end-effector accuracy and grasping still need acceptance.